 Toolbox
Z18N GPS module specifications
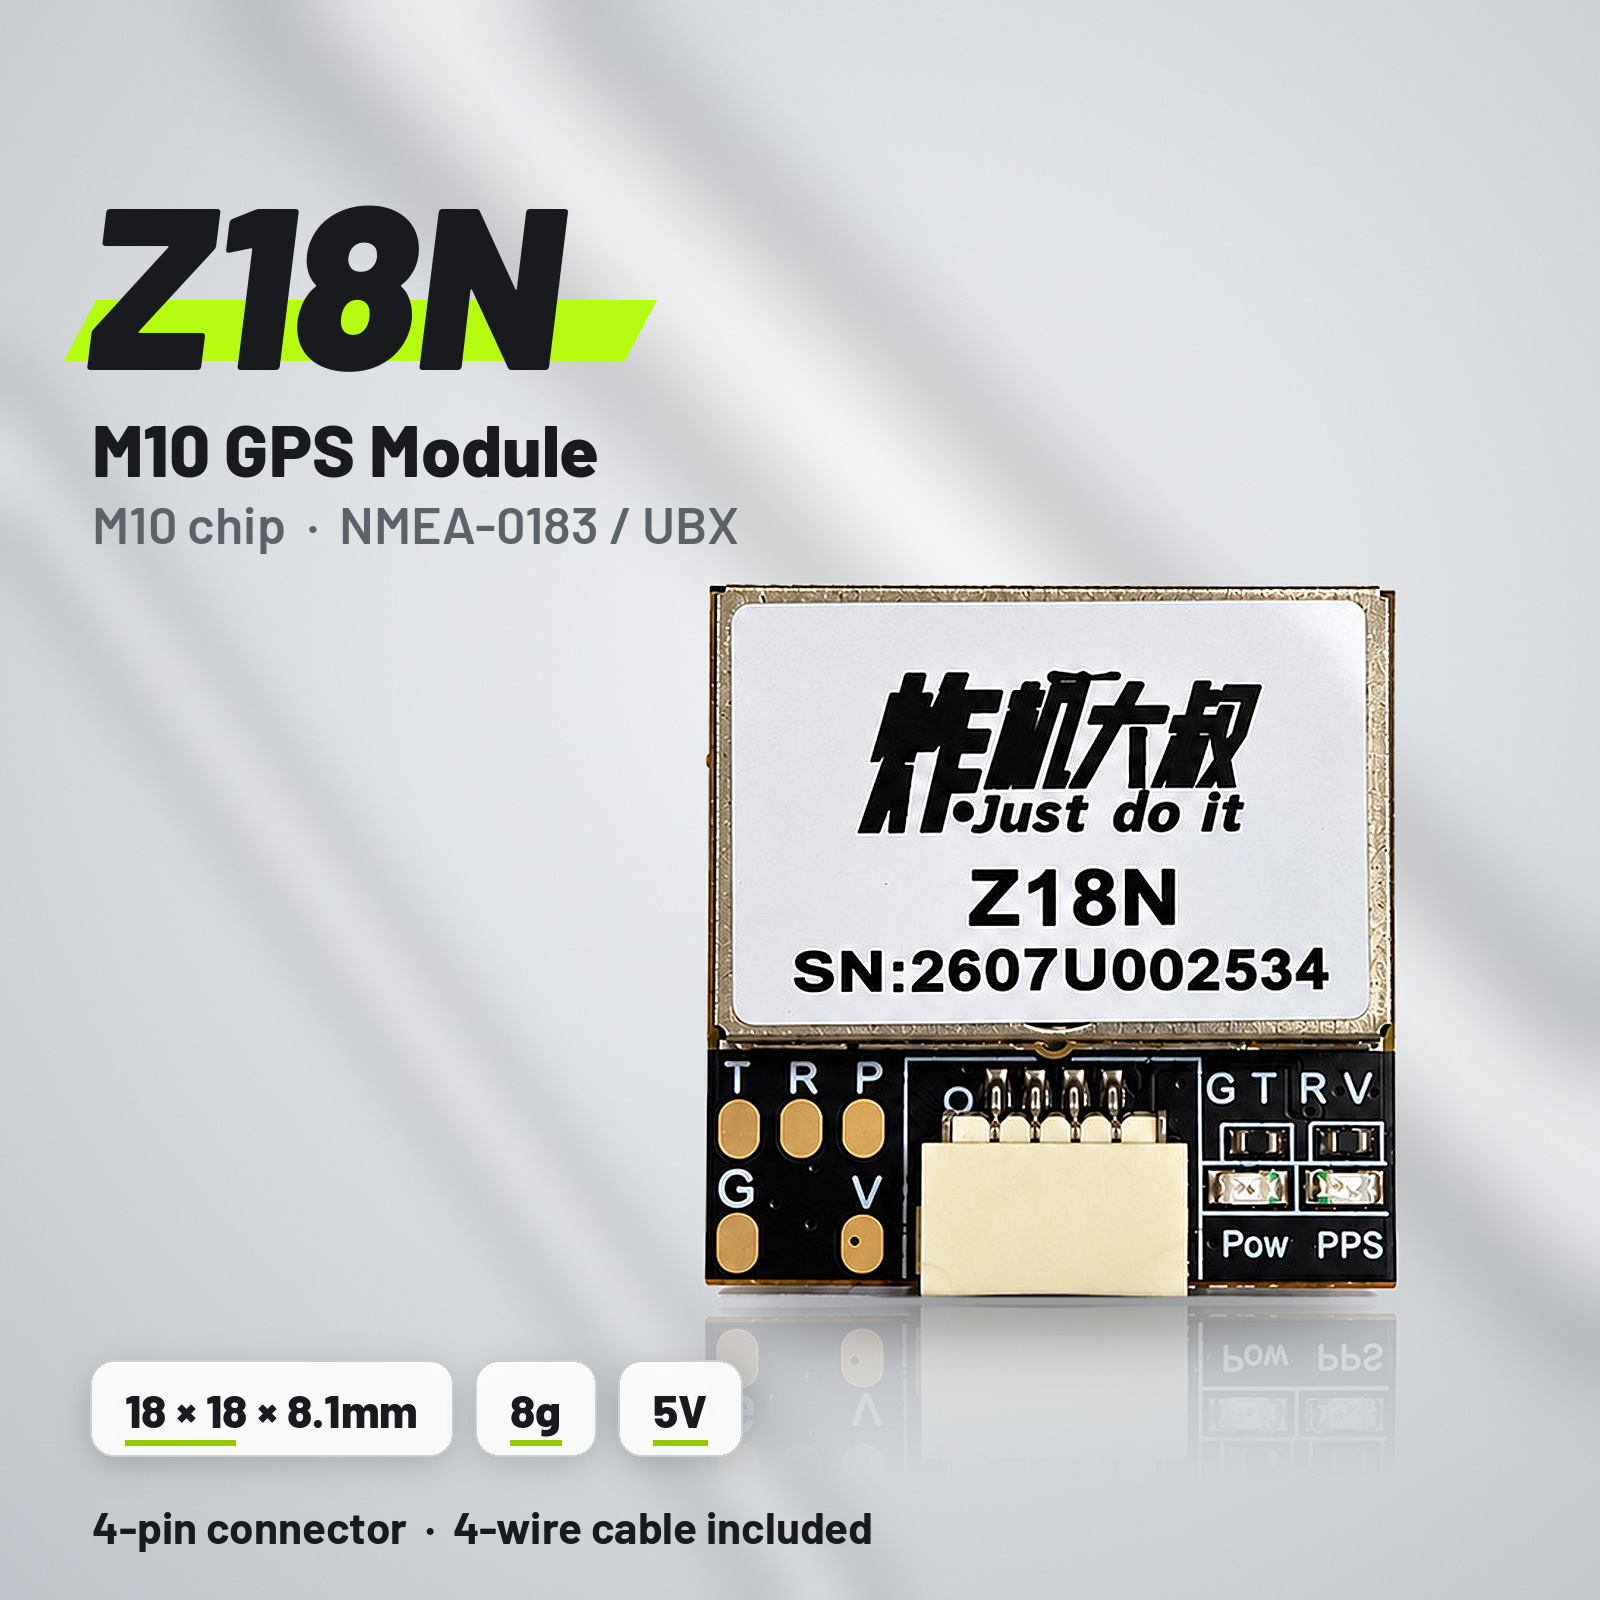
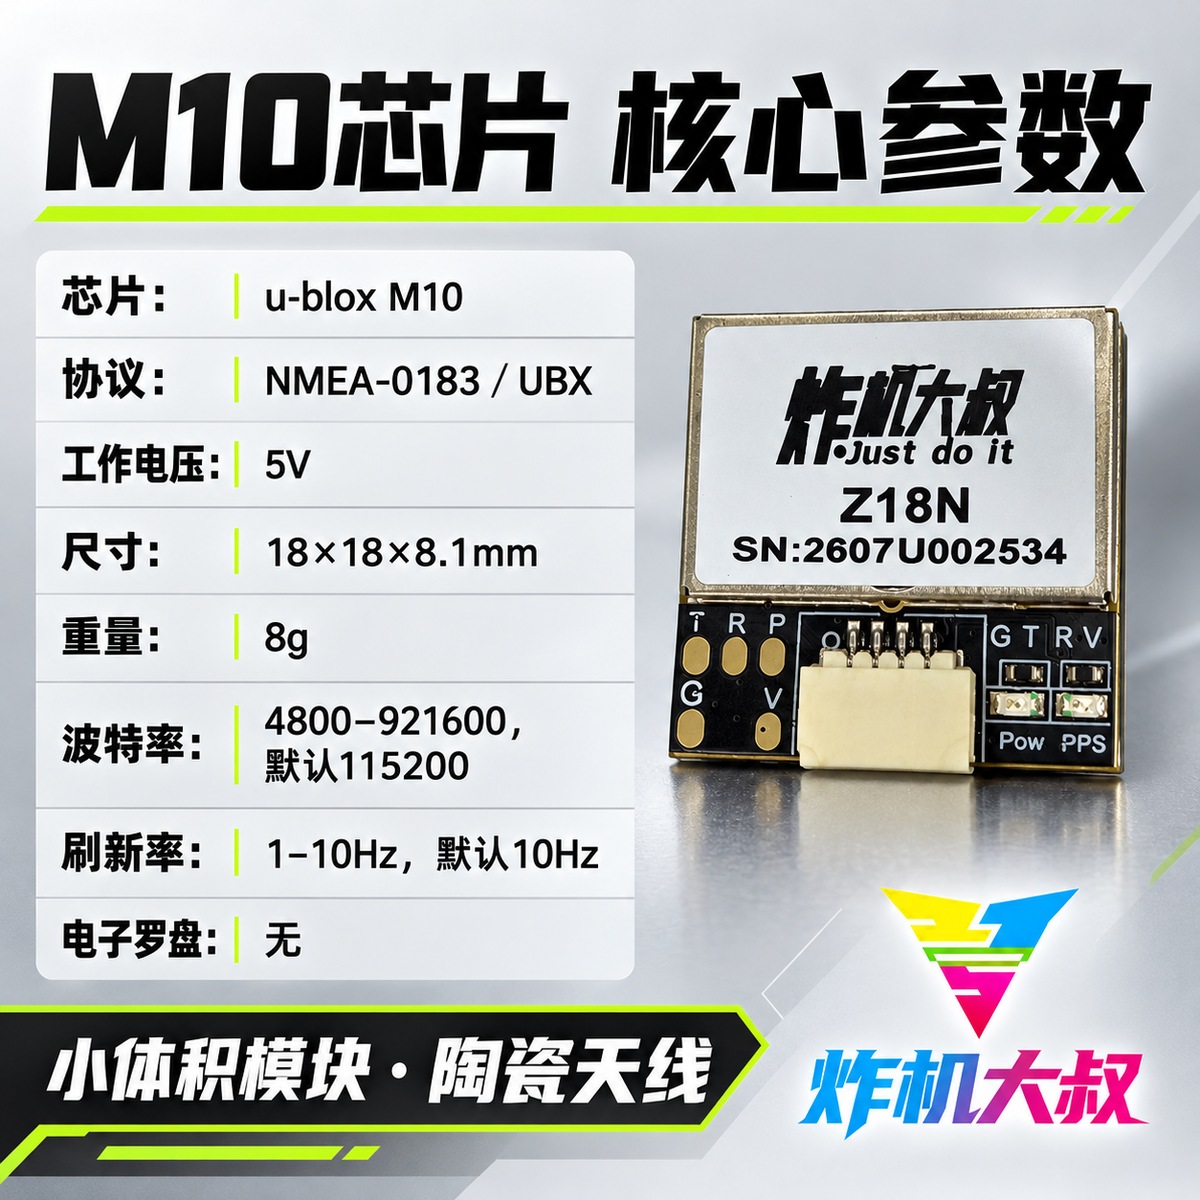
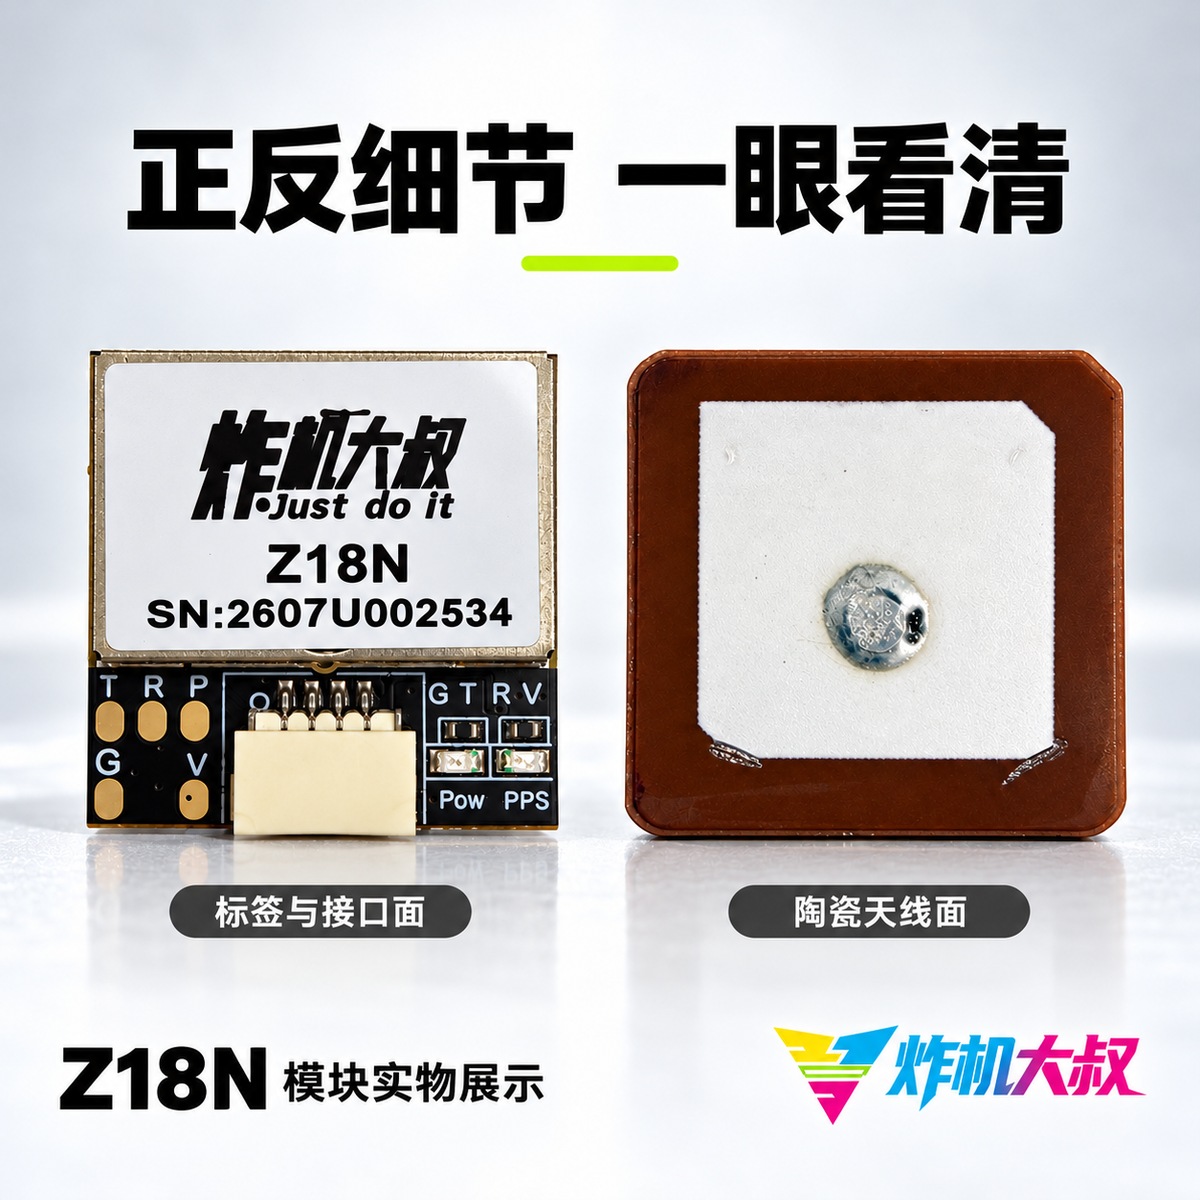
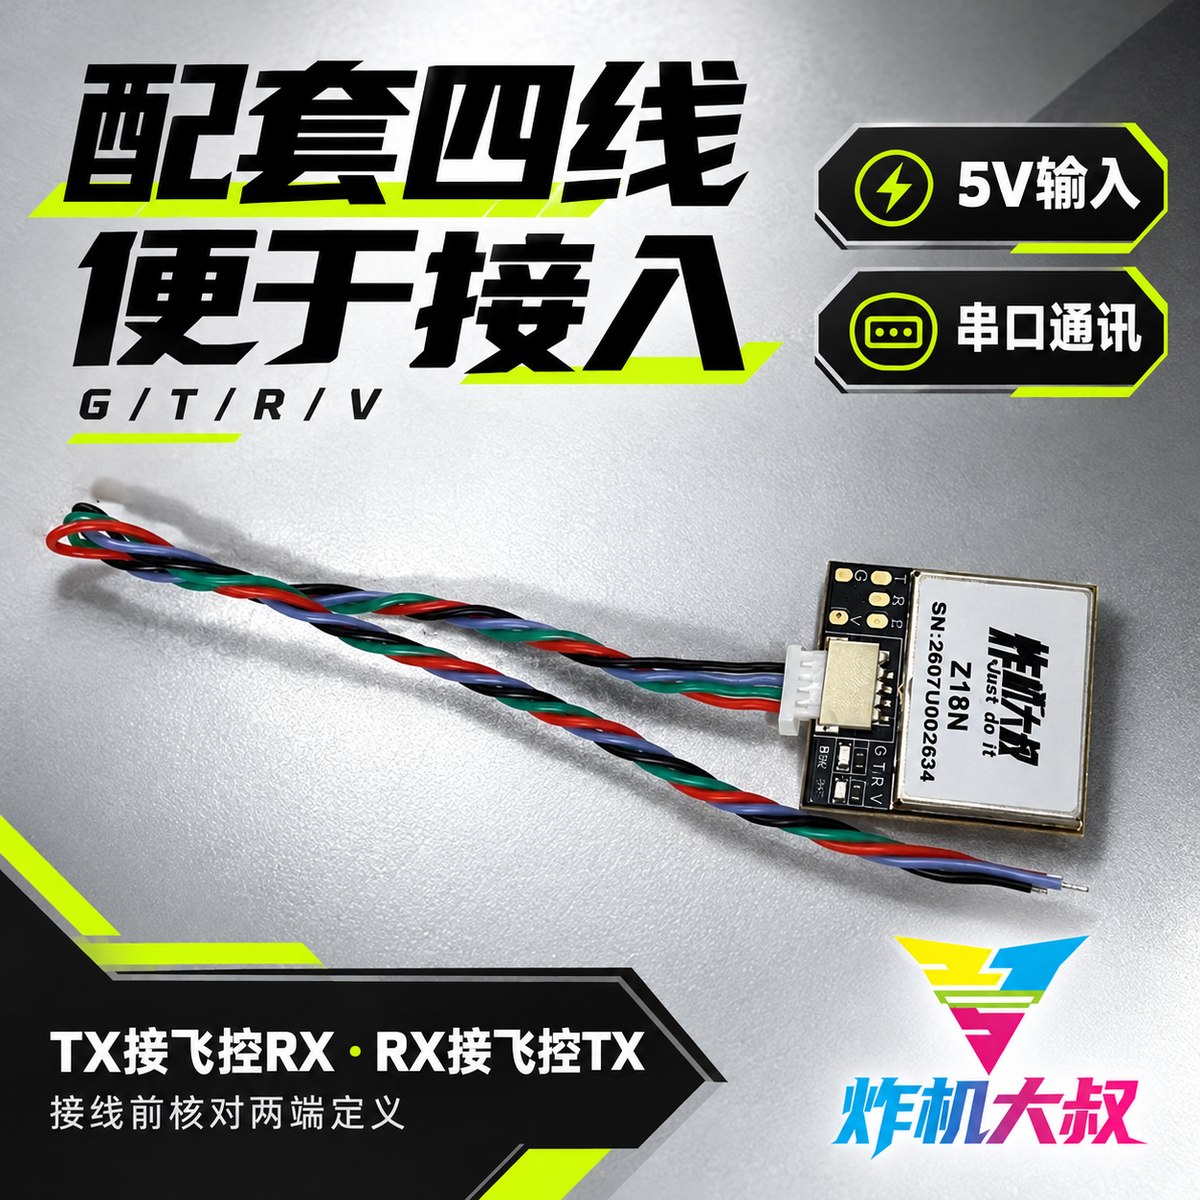
The BOOMFPV(炸机大叔) Z18N GPS module comes with a four-pin connector and a matching four-wire harness. It uses a u-blox M10, supports NMEA-0183 / UBX, takes a 5V input, and is specified at 18×18×8.1mm and 8g, with no magnetometer. The figures above come from data provided to us and have not been independently measured or tested.
Serial port and refresh rate
The supplied data lists a baud rate of 4800–921600, default 115200, and a refresh rate of 1–10Hz, default 10Hz. When you connect it to a flight controller, check the UART you are using and the protocol, baud rate, and function settings on both ends.
Four-pin connector orientation and wiring
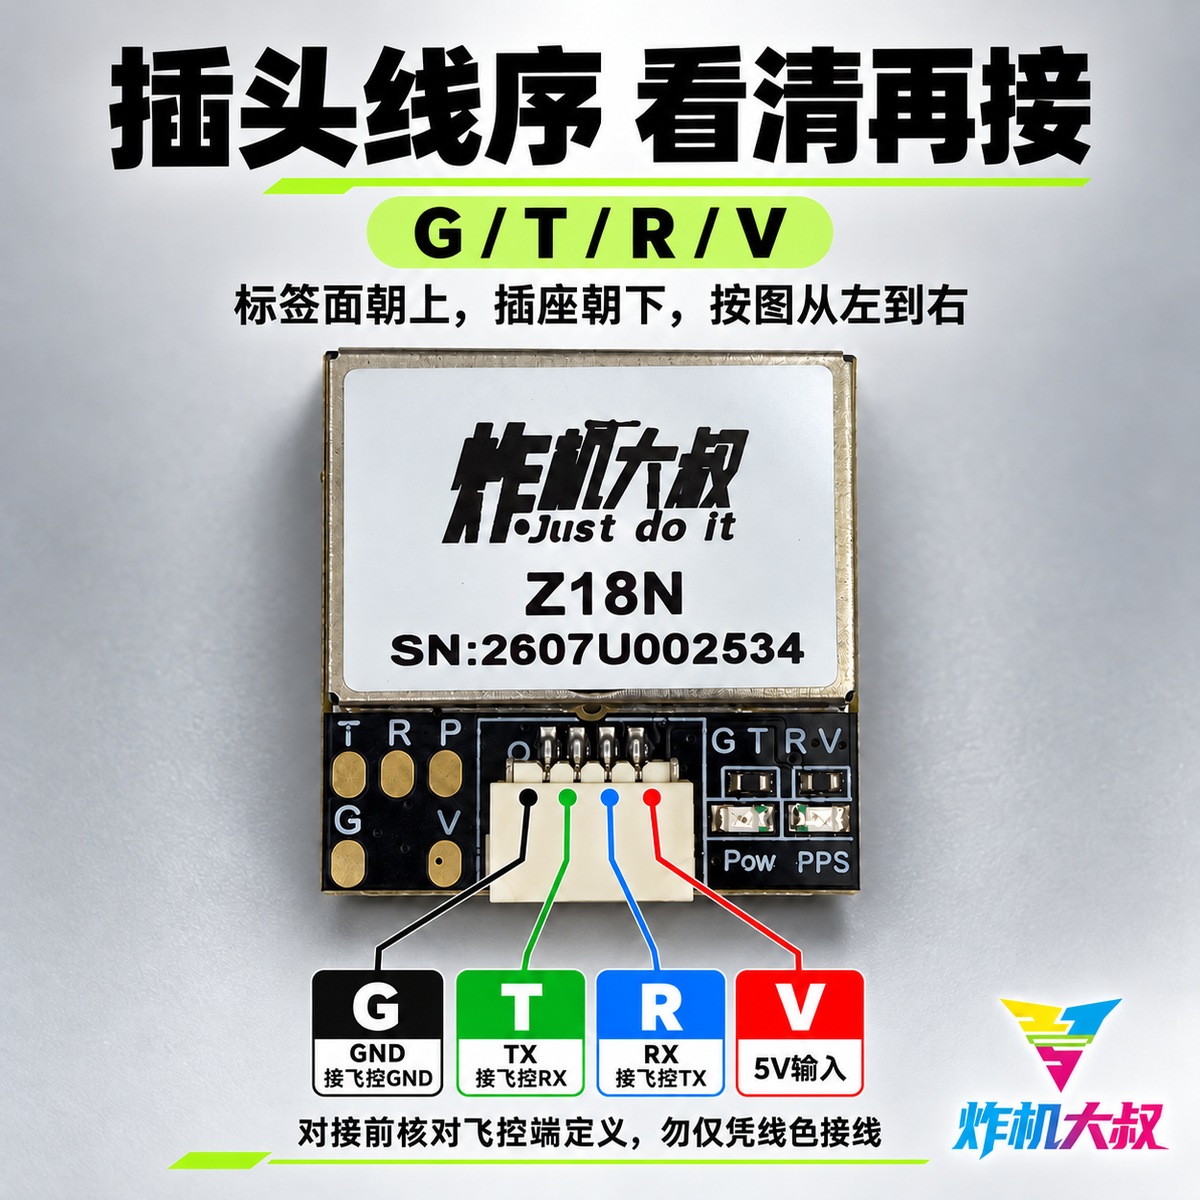
With the label facing up and the socket facing down, the pins from left to right in the photo are G / T / R / V. G is GND, to flight-controller GND. T is module TX, to flight-controller RX. R is module RX, to flight-controller TX. V is 5V input. Check the flight-controller pinout before you connect it. Do not wire by lead color alone.
Positioning and status
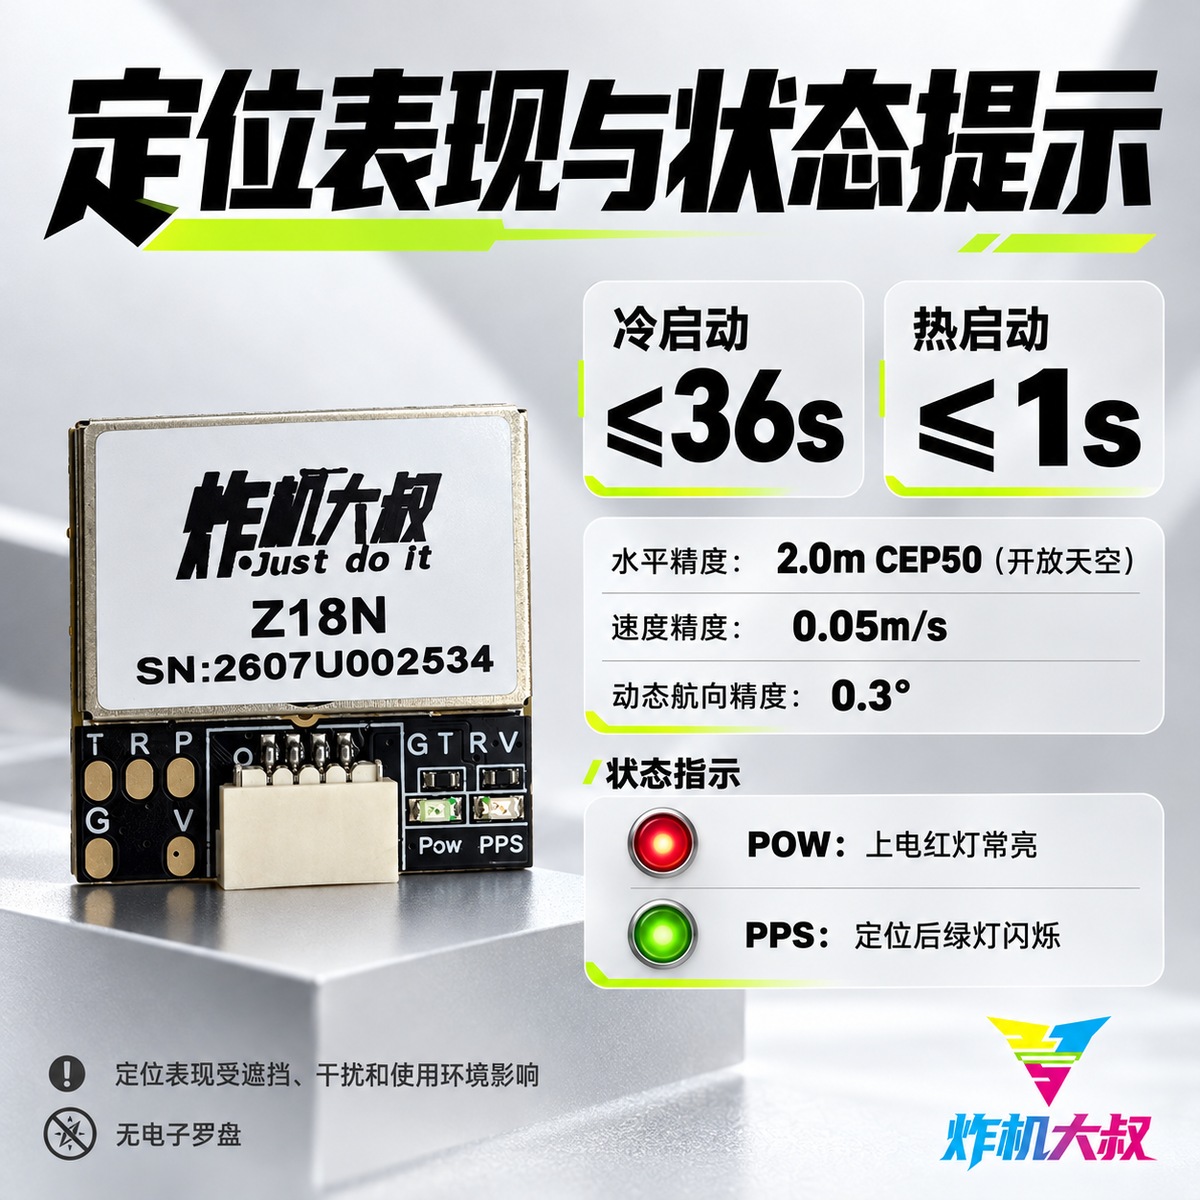
Supplied specifications: cold start ≤36s, hot start ≤1s; open-sky horizontal accuracy 2.0m CEP50, speed accuracy 0.05m/s, dynamic heading accuracy 0.3°. These are supplied specification values, not independently measured. Positioning depends on obstruction, interference, and the environment. This is not a guarantee of a fixed start time or of return-to-home. Dynamic heading accuracy does not mean the module has a magnetometer.
Indicator LEDs and the included harness
POW: red LED stays on when power is applied. PPS: green LED flashes after a fix. The included four-wire harness is for 5V power and serial communication, with TX/RX crossed. Check the harness ends against the definitions on both sides.